CRAWLER / DAM & INTAKE INSPECTION
A-400
Swim to the structure, then hold position on it.
A 400 kg tracked underwater robot that switches between swimming and crawling on submerged structures, for dam, intake and hydropower inspection to 300 m.
Get a configuration & quote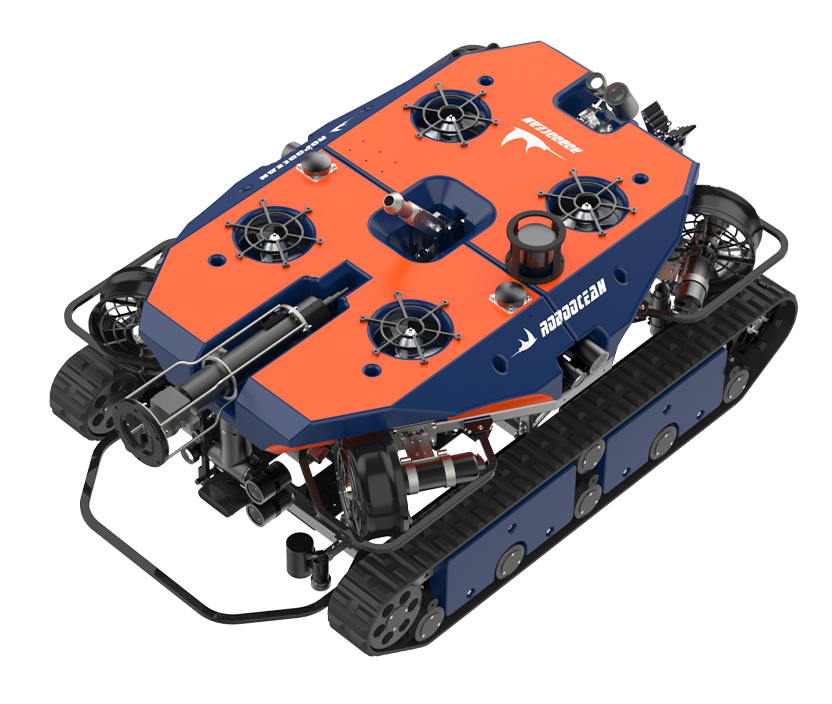 Manufacturer product rendering · Boya Gongdao
TECHNICAL STARTING POINT
Key specifications.
- Vehicle weight
- 400 kg
- Depth rating
- 300 m
- Motion modes
- Free swimming + tracked crawling
- Dimensions
- 1,800 × 1,200 × 750 mm
- Thrusters
- 8 (4 horizontal vector + 4 vertical)
- Cameras
- 1080p front, rear, left and right
- Power
- External tethered supply
Tasks to assess
- Dam faces, intakes and gates where a free-swimming ROV struggles to hold position
- Routine large-area defect surveys with position and size records
- Offshore wind foundations, assessed project by project
Configuration checks
- Confirm how the robot holds to the surface and which substrates it has been tested on: concrete, steel or fouled surfaces.
- Provide flow conditions at the structure; operating current limits must be confirmed for the supplied version.
- Agree defect types, positioning method and the export format of logged inspection data.
COMPLETE SYSTEM
Specify more than
the vehicle.
Sonar and a manipulator are optional items purchased separately. The manufacturer describes logged inspection data for comparing surveys over time; request sample data before relying on it for asset reporting. Launch and recovery of a 400 kg vehicle needs lifting equipment and a planned access point.
Confirm in the delivered scope
- Vehicle and installed payload
- Control station and software functions
- Tether length, reel and power supply
- Selected tools, sensors and deployment equipment
- Transport cases, spares, manuals and training
Standard, optional and custom items must be listed separately in the quotation.
Browse ROV tools & accessoriesQUESTIONS
Before you specify the A-400.
Why choose a crawler instead of a free-swimming ROV?
Crawling on the structure can give a steadier camera position for close inspection where flow or surface geometry makes station-keeping difficult. It adds requirements for surface condition, access and launch equipment.
Has it been used on hydropower structures?
The manufacturer reports a dual-mode inspection robot developed for China Yangtze Power to inspect submerged hydropower structures. The case study explains what that reference does and does not establish.
PROCUREMENT
Prepare the next review.
Agree the site conditions, acceptance test, delivery scope and support responsibilities. Product names and rated figures alone are not a project specification.
A-400 starting brief
Download a concise summary of the specifications and project questions shown here. This is a selection aid, not a factory-approved datasheet.
Download product briefFROM TASK TO CONFIGURATION
Bring your project into focus.
Share the task, site conditions and required results. Build a clear brief for system selection.